import gymnasium as gym
import lwmr  # noqa: F401 <-- register the environment
import matplotlib.pyplot as plt
import numpy as np
from IPython.display import HTML
from matplotlib.animation import FuncAnimation
from matplotlib.patches import Polygon
from tqdm.auto import trangeTesting Simulation
# Specifying the path so that the recording is saved in the project root.
viewer_output_path = "../recordings/lwmr_plane.viser"
env = gym.make(
    "lwmr/Lwmr-v0",
    quiet=True,
    render_mode="viser",
    viewer_output_path_stem=viewer_output_path,
    max_steps=400,
)
2026-10-09 11:46:13.763 | WARNING | lwmr.envs.plane:__init__:68 - CUDA device specified but not available, falling back to CPU
stopped = (0.0, 0.0, 0.0, 0.0)
forward = (1.0, 1.0, 1.0, 1.0)
veer_right = (1.0, 0.5, 1.0, 0.5)
veer_left = (0.5, 1.0, 0.5, 1.0)
rotate_left = (-1.0, 1.0, -1.0, 1.0)
rotate_right = (1.0, -1.0, 1.0, -1.0)


def waypoint_hit(info):
    return info.get("event") == "waypoint_hit" or info.get("event") == "finished"


def yaw_reached(target):
    return lambda info: abs(info["yaw"] - target) < 0.02


state_machine = [
    {"action": forward, "condition": waypoint_hit, "next": 1},
    {"action": rotate_left, "condition": yaw_reached(np.pi / 2), "next": 2},
    {"action": forward, "condition": waypoint_hit, "next": 3},
    {"action": rotate_right, "condition": yaw_reached(0.0), "next": 4},
    {"action": forward, "condition": waypoint_hit, "next": 5},
    {"action": stopped, "condition": lambda info: False, "next": -1},
]
action_index = 0
all_obs = []
all_info = []
rewards = []
env.reset()
num_steps = env.unwrapped.max_steps # type: ignore
for step in trange(num_steps):
action = state_machine[action_index]["action"]
obs, reward, terminated, truncated, info = env.step(action=action)
all_obs.append(obs.copy())
all_info.append(info.copy())
rewards.append(reward)
env.render()
if info.get("event"):
print(f"Event at step {step:3d}: {info['event']}")
if terminated or truncated:
print(f"Episode ended at step {step}")
break
if state_machine[action_index]["condition"](info):
action_index = state_machine[action_index]["next"]
env.close()
  0%|          | 0/400 [00:00<?, ?it/s]
   ⋮ (27 progress updates omitted)
Event at step 88: waypoint_hit
100%|█████████▉| 399/400 [00:03<00:00, 132.30it/s]Episode ended at step 399(viser) Server stopped
print("All info keys:")
for name in all_info[0]:
    print("-", name)
All info keys:
- pos
- yaw
- vel
- distcumulative_reward = np.sum(rewards)
plt.plot(rewards)
plt.xlabel("Step")
plt.ylabel("Reward")
plt.title(f"LWMR Rewards over Time: Cumulative Reward = {cumulative_reward:.2f}");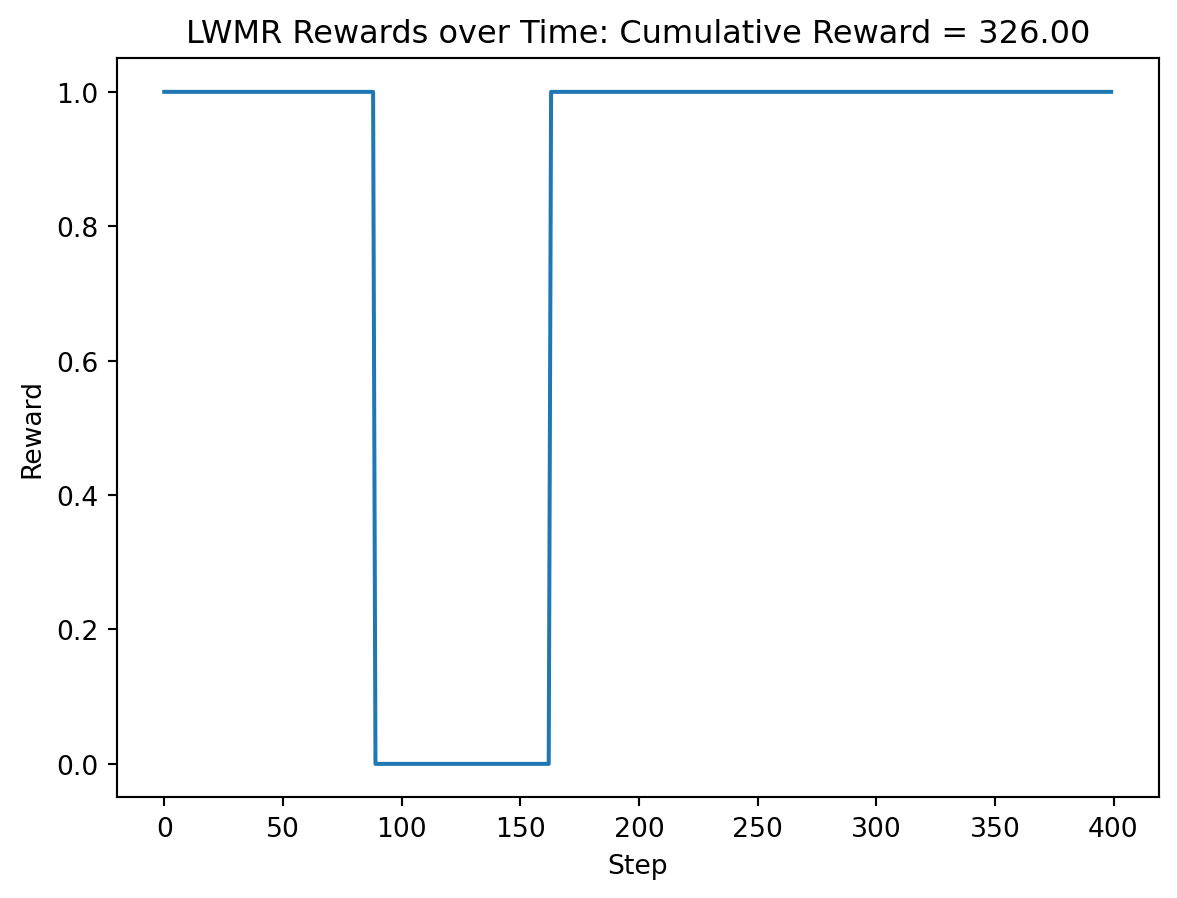
# Plot all info: dict of pos, yaw, vel, dist, events
# Plot all obs: array of
#  [ 0: 2]   body frame velocity (v_x, v_y)
#  [    2]     angular velocity (omega)
#  [ 3: 5]   heading sin/cos
#  [ 5:14]  relative position to waypoint (x_rel, y_rel, magnitude)
#  [   14]    progress
#  [   15]    cross track error
#  [16:20] previous action (4 values)

down_sample = 10

fig, (ax1, ax2) = plt.subplots(nrows=2)

xs = np.array([pose["pos"][0] for pose in all_info[::down_sample]])
ys = np.array([pose["pos"][1] for pose in all_info[::down_sample]])
yaws = np.array([pose["yaw"] for pose in all_info[::down_sample]])
dists = np.array([pose["dist"] for pose in all_info[::down_sample] if "dist" in pose])

# Plot the trajectory line
ax1.plot(xs, ys, "b-", alpha=0.5, label="Path")
ax1.plot(0.5, 0.0, "ro", label="Waypoint")
ax1.plot(0.5, 0.5, "ro", label="Waypoint")
ax1.plot(1.0, 0.5, "ro", label="Waypoint")

# Plot heading arrows using quiver
u = np.cos(yaws)  # x-component of heading
v = np.sin(yaws)  # y-component of heading
ax1.quiver(xs, ys, u, v, color="red", scale=20, width=0.005, label="Heading")

ax1.axis("equal")
ax1.grid(True)
ax1.set_xlabel("x")
ax1.set_ylabel("y")
ax1.set_title("Trajectory with Heading")
ax1.legend()

ax2.plot(dists, "g-")
ax2.set_xlabel("timestep")
ax2.set_ylabel("distance")
ax2.set_title("Distance to Goal")

plt.tight_layout();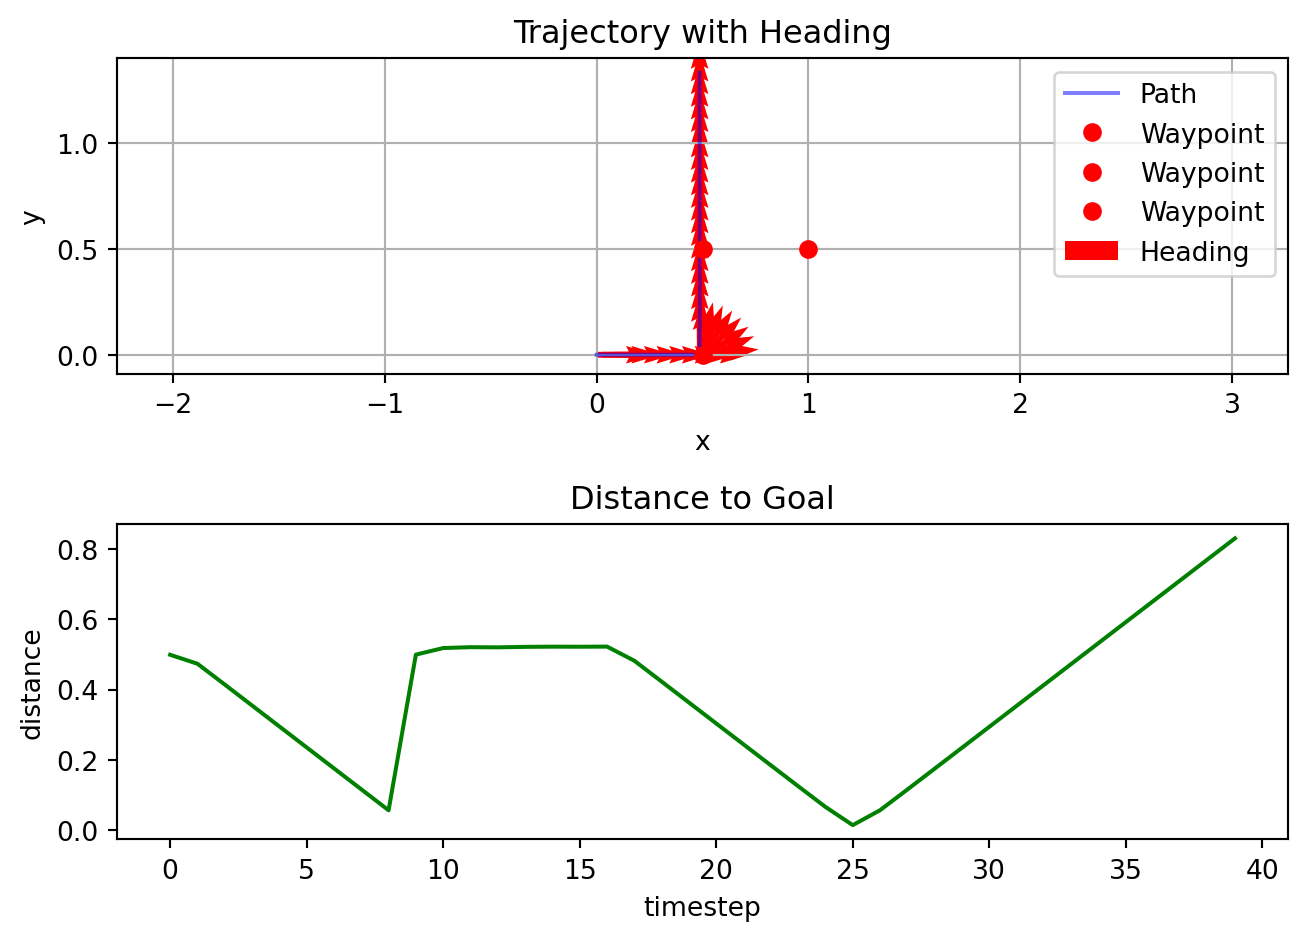
fig, axes = plt.subplots(8, 1, figsize=(8, 14))

obs = np.vstack(all_obs)

axes[0].plot(obs[:, 0], label="xdrel")
axes[0].plot(obs[:, 1], label="ydrel")
axes[0].set_xlabel("timestep")
axes[0].legend()

axes[1].plot([pose["vel"][0] for pose in all_info], label="xvel")
axes[1].plot([pose["vel"][1] for pose in all_info], label="yvel")
axes[1].set_xlabel("timestep")
axes[1].set_ylabel("velocity")
axes[1].legend()

axes[2].plot(np.linalg.norm(obs[:, :2], axis=1), label="xd")
axes[2].plot([np.linalg.norm(pose["vel"][:2]) for pose in all_info], label="speed")
axes[2].set_xlabel("timestep")
axes[2].set_ylabel("speed")
axes[2].legend()

axes[3].plot([pose["yaw"] for pose in all_info])
axes[3].set_xlabel("timestep")
axes[3].set_ylabel("heading (rad)")

axes[4].plot(obs[:, 3], label="heading_sin")
axes[4].plot(obs[:, 4], label="heading_cos")
axes[4].set_xlabel("timestep")
axes[4].set_ylabel("heading sin/cos")
axes[4].legend()

axes[5].plot(obs[:, 2], label="omega")
axes[5].set_xlabel("timestep")
axes[5].set_ylabel("angular velocity (rad/s)")

axes[6].plot(obs[:, 14], label="progress")
axes[6].set_ylabel("progress")

axes[7].plot(obs[:, 15], label="cross track error")
axes[7].set_xlabel("timestep")
axes[7].set_ylabel("cross track error")

plt.tight_layout();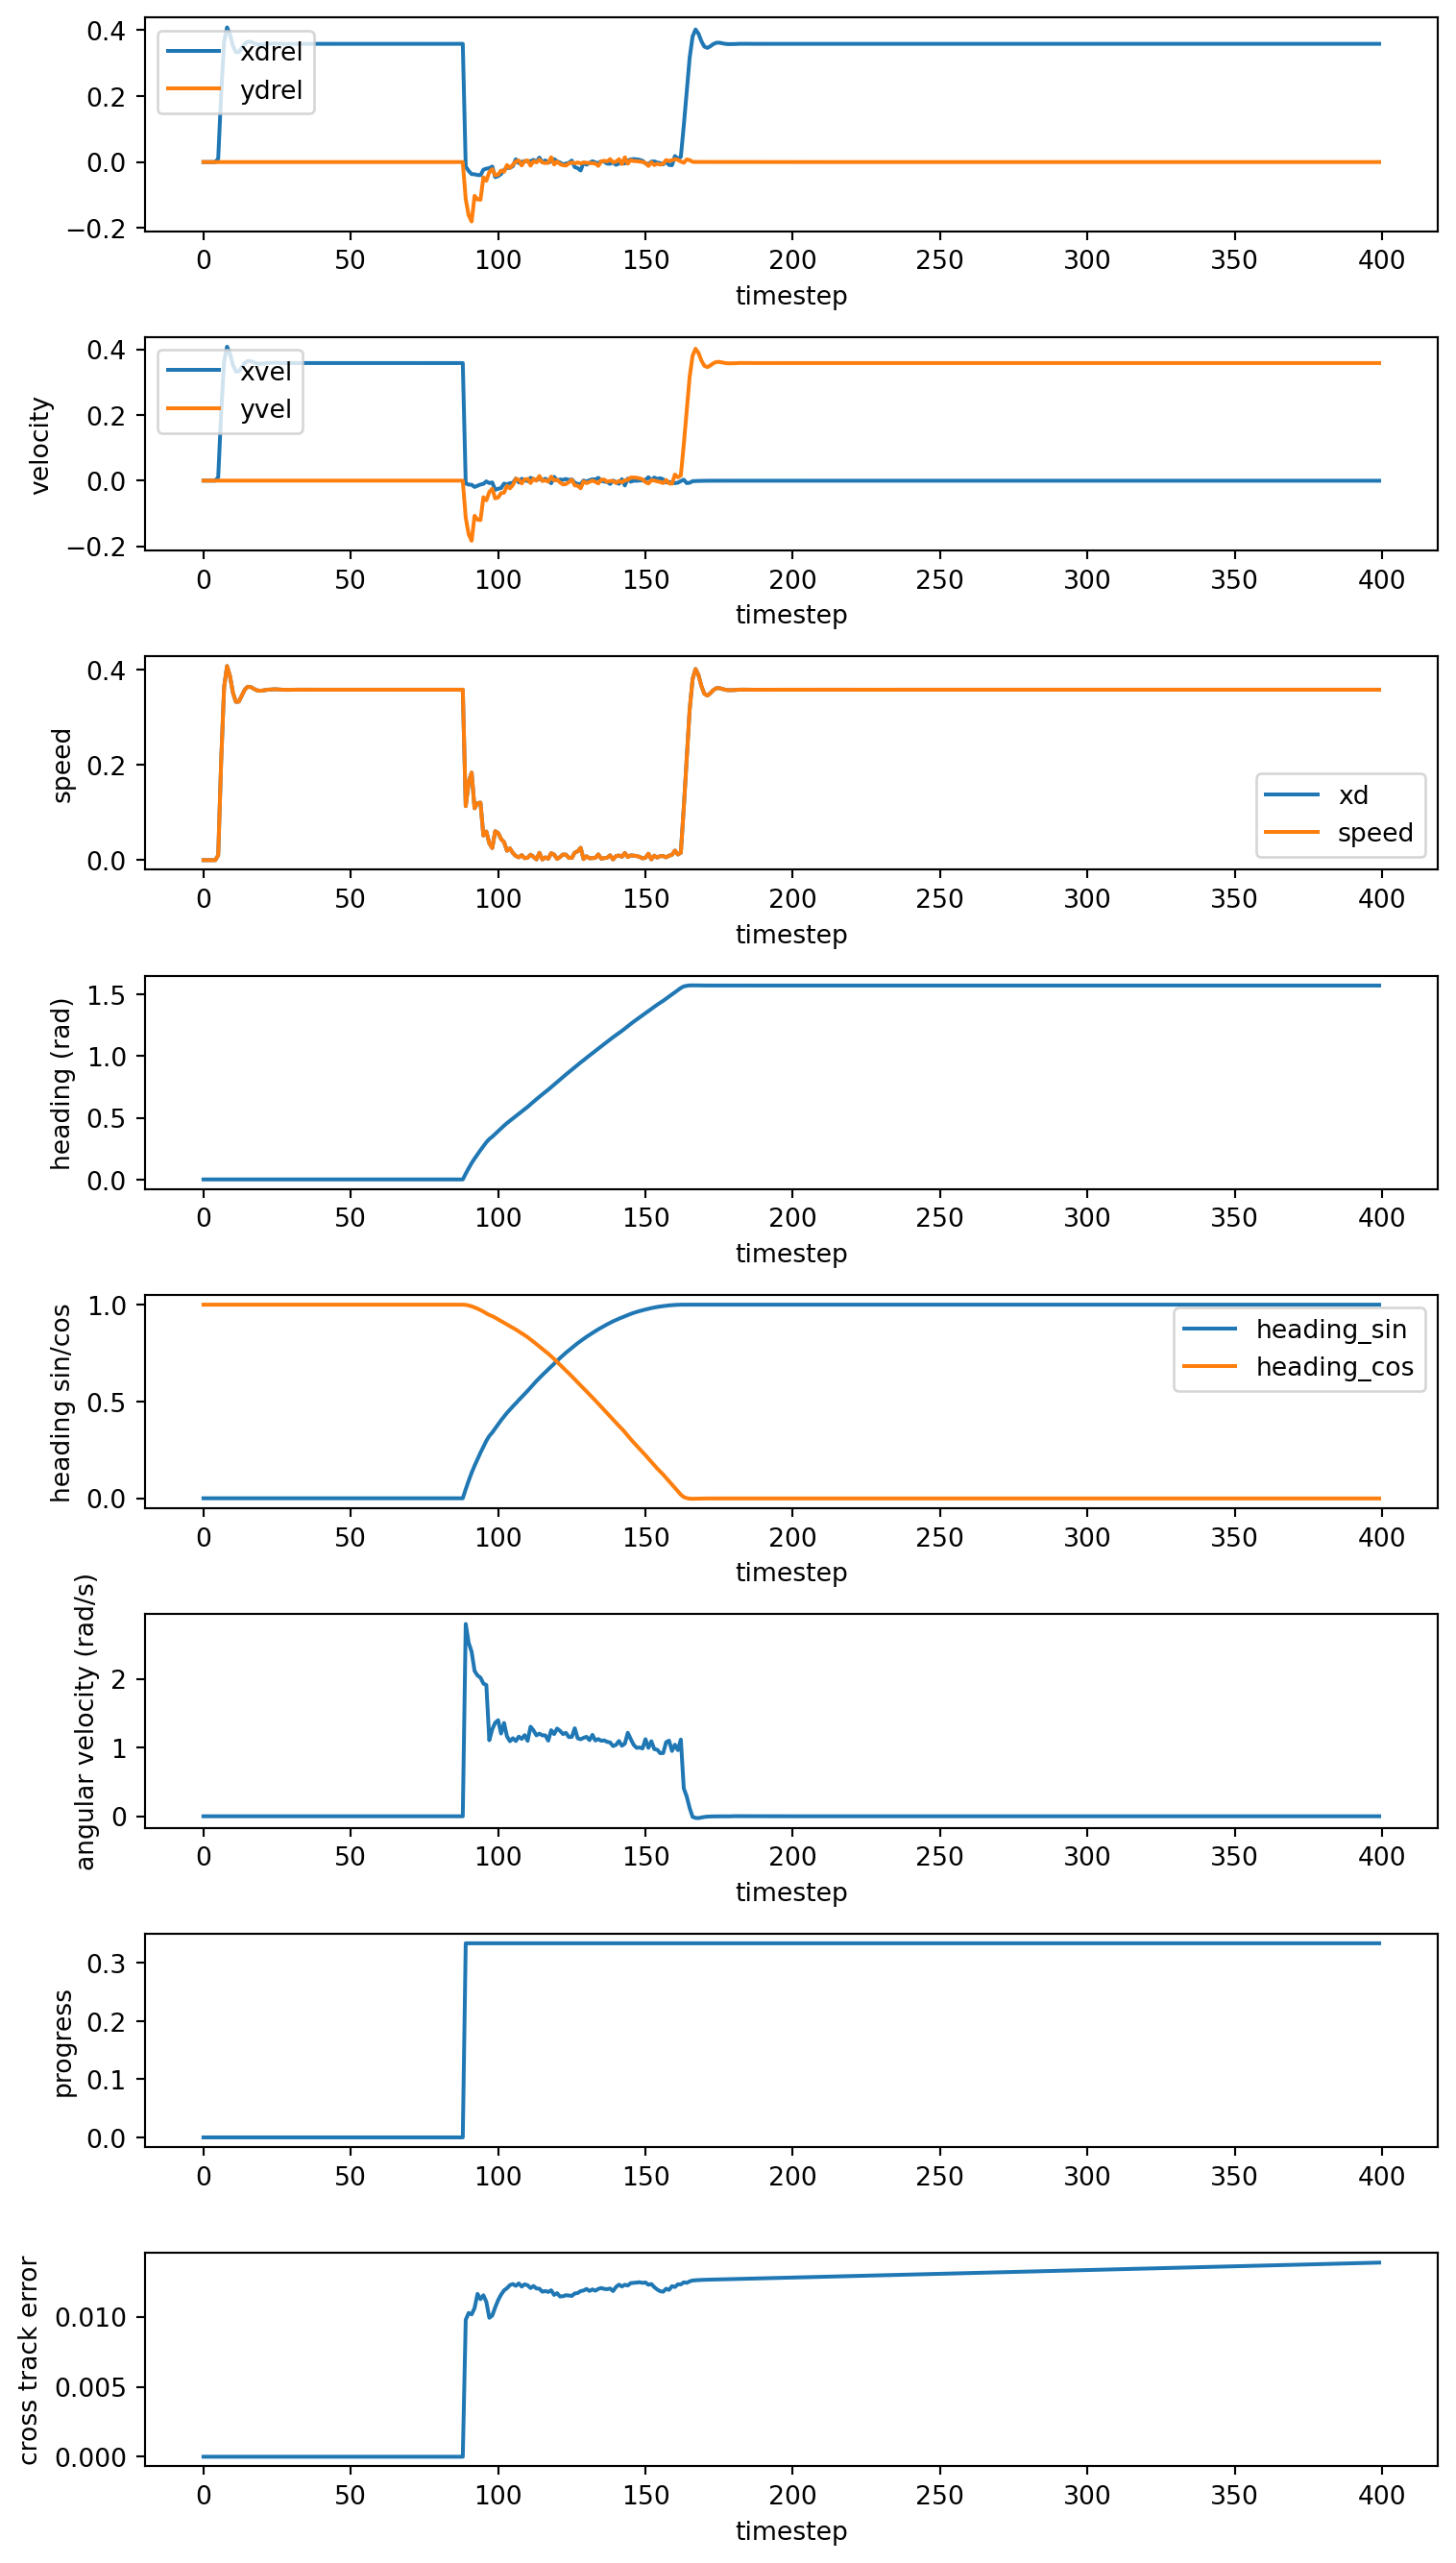
fig, axes = plt.subplots(nrows=3, figsize=(10, 8))

axes[0].plot(obs[:, 5], label="x_rel")
axes[0].plot(obs[:, 6], label="y_rel")
axes[0].plot(obs[:, 7], label="magnitude")
axes[0].set_xlabel("timestep")
axes[0].set_ylabel("relative position to waypoint")
axes[0].legend()

axes[1].plot(obs[:, 8], label="x_rel")
axes[1].plot(obs[:, 9], label="y_rel")
axes[1].plot(obs[:, 10], label="magnitude")
axes[1].set_xlabel("timestep")
axes[1].set_ylabel("relative position to waypoint")
axes[1].legend()

axes[2].plot(obs[:, 11], label="x_rel")
axes[2].plot(obs[:, 12], label="y_rel")
axes[2].plot(obs[:, 13], label="magnitude")
axes[2].set_xlabel("timestep")
axes[2].set_ylabel("relative position to waypoint")
axes[2].legend()

plt.tight_layout();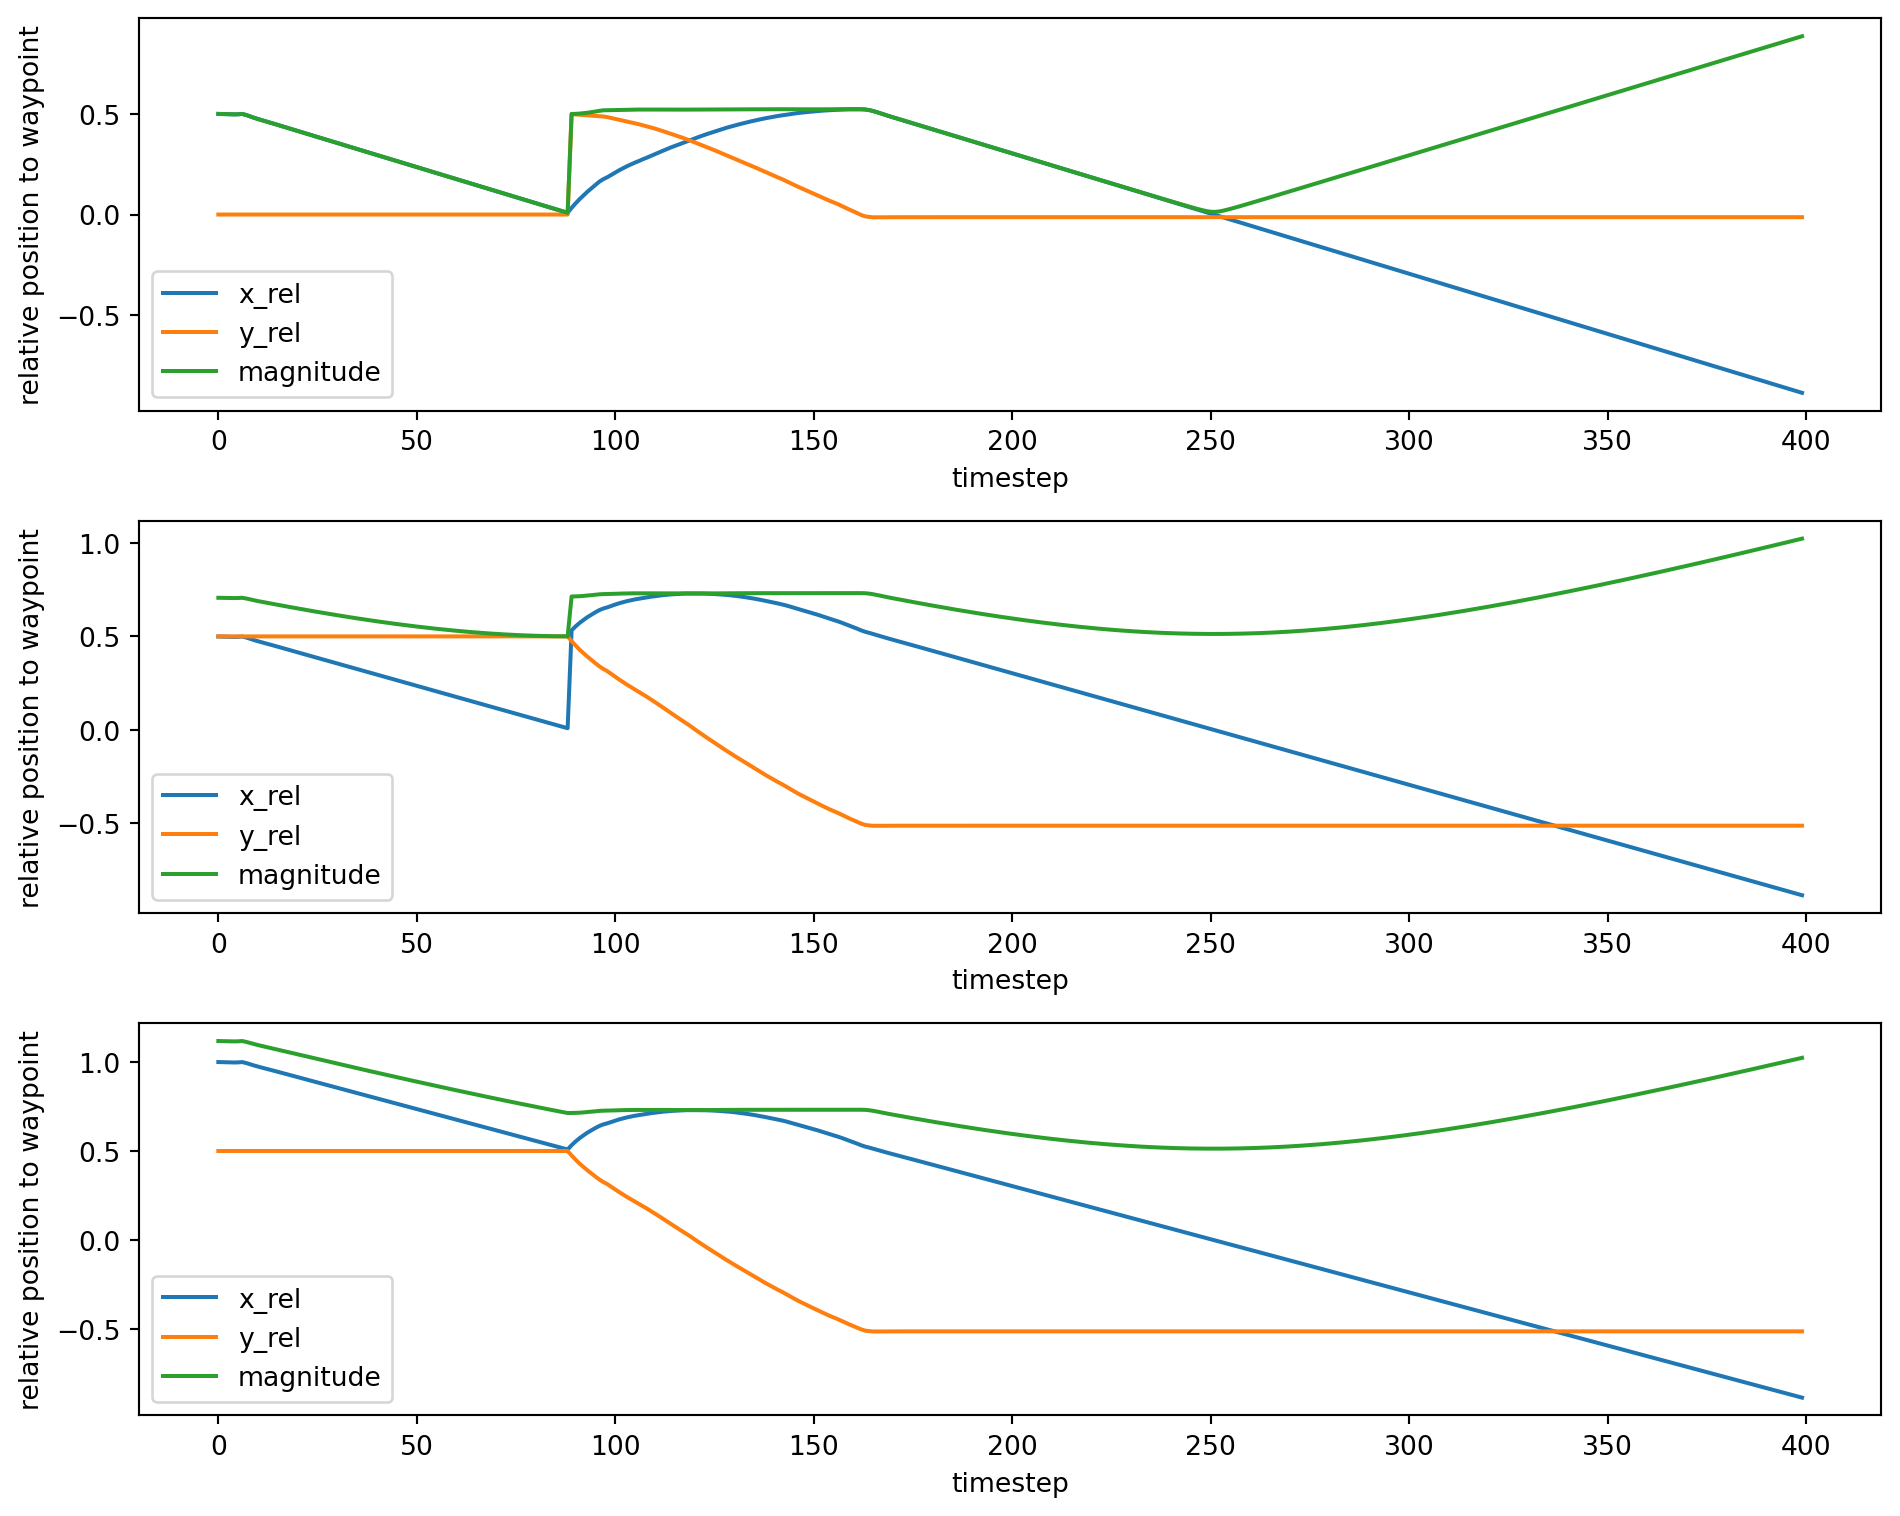
def animate_trajectory(
    xs,
    ys,
    yaws,
    interval=40,
    max_frames=500,
    triangle_size=0.1,
    arrow_len=0.2,
    trail=True,
    figsize=(8, 6),
):
    xs = xs[:max_frames]
    ys = ys[:max_frames]
    yaws = yaws[:max_frames]

    fig, ax = plt.subplots(figsize=figsize)

    # Set fixed axis limits with padding so the view doesn't jump around
    pad = 0.5
    ax.set_xlim(xs.min() - pad, xs.max() + pad)
    ax.set_ylim(ys.min() - pad, ys.max() + pad)
    ax.set_aspect("equal")
    ax.grid(True, alpha=0.3)
    ax.set_xlabel("x")
    ax.set_ylabel("y")
    ax.set_title("Animated Trajectory")

    # Faint full path for reference
    ax.plot(xs, ys, color="lightgray", linewidth=1, zorder=1)

    # Trail (path traced so far)
    (trail_line,) = ax.plot([], [], "b-", linewidth=2, zorder=2)

    # Heading arrow
    heading_arrow = ax.quiver(
        [xs[0]],
        [ys[0]],
        [np.cos(yaws[0])],
        [np.sin(yaws[0])],
        color="red",
        scale=1 / arrow_len,
        scale_units="xy",
        angles="xy",
        width=0.006,
        zorder=4,
    )

    # Pose triangle
    ts = triangle_size
    base_tri = np.array([[ts, 0], [-ts / 2, ts / 2], [-ts / 2, -ts / 2]])

    def rotate_translate(pts, xc, yc, theta):
        c, s = np.cos(theta), np.sin(theta)
        R = np.array([[c, -s], [s, c]])
        return pts @ R.T + np.array([xc, yc])

    xy = rotate_translate(base_tri, xs[0], ys[0], yaws[0])
    pose_patch = Polygon(xy, closed=True, color="blue", alpha=0.7, zorder=3)
    ax.add_patch(pose_patch)

    # Step / time text
    bbox = dict(boxstyle="round", facecolor="white", alpha=0.8)
    txt = ax.text(0.02, 0.98, "", transform=ax.transAxes, va="top", ha="left", bbox=bbox)

    def init():
        trail_line.set_data([], [])
        return trail_line, heading_arrow, pose_patch, txt

    def update(i):
        if trail:
            trail_line.set_data(xs[: i + 1], ys[: i + 1])

        # Update heading arrow position + direction
        heading_arrow.set_offsets(np.array([[xs[i], ys[i]]]))
        heading_arrow.set_UVC(np.cos(yaws[i]), np.sin(yaws[i]))

        # Update pose triangle
        pose_patch.set_xy(rotate_translate(base_tri, xs[i], ys[i], yaws[i]))

        txt.set_text(f"step: {i + 1}/{len(xs)}\nx={xs[i]:.2f}, y={ys[i]:.2f}, yaw={np.degrees(yaws[i]):.1f}°")
        return trail_line, heading_arrow, pose_patch, txt

    anim = FuncAnimation(fig, update, frames=len(xs), init_func=init, interval=interval, blit=False)
    plt.close(fig)  # prevents duplicate static figure in Jupyter
    return anim


anim = animate_trajectory(xs, ys, yaws, interval=40)
HTML(anim.to_jshtml())
# anim.save('trajectory.mp4', fps=25)  # optional: save to file (needs ffmpeg)